Research & Development
Robotics, laser metrology, and simulation-driven inspection systems for the oil & gas industry.
Scroll
Research & Development
Robotics, laser metrology, and simulation-driven inspection systems for the oil & gas industry.
Overview
ModusXLabs is MODUS's second research team, building end-to-end solutions that combine hardware design, ROS-based robotics software, 3D scanning, point cloud processing, and gauge measurement algorithms — primarily targeting drill bit inspection for clients like Saudi Aramco.
The team takes a simulation-first approach: every system is fully validated in a digital twin before field deployment, reducing iteration cost and accelerating time to market.
Core Capabilities
Operates 2D laser profilers (Micro-Epsilon scanControl 2500 series) to capture high-resolution surface profiles. Generates dense 3D point clouds with up to ~3.3 million points per scan by accumulating profiles while the drill bit rotates on a controlled rotary stage. Covers drill bits from 3 5/8" to 8 1/2" across multiple manufacturers including SLB, Beste, and Ulterra.
Custom algorithm to determine drill bit gauge condition from point cloud data. The process segments point clouds into 1 mm vertical slices, computes minimum enclosing circles per slice, and identifies the largest radius as the measured gauge. Compares against nominal size to classify wear levels (I, 1/16, 2/16, etc.) with accuracy within ~0.06–2.09 mm of nominal diameter.
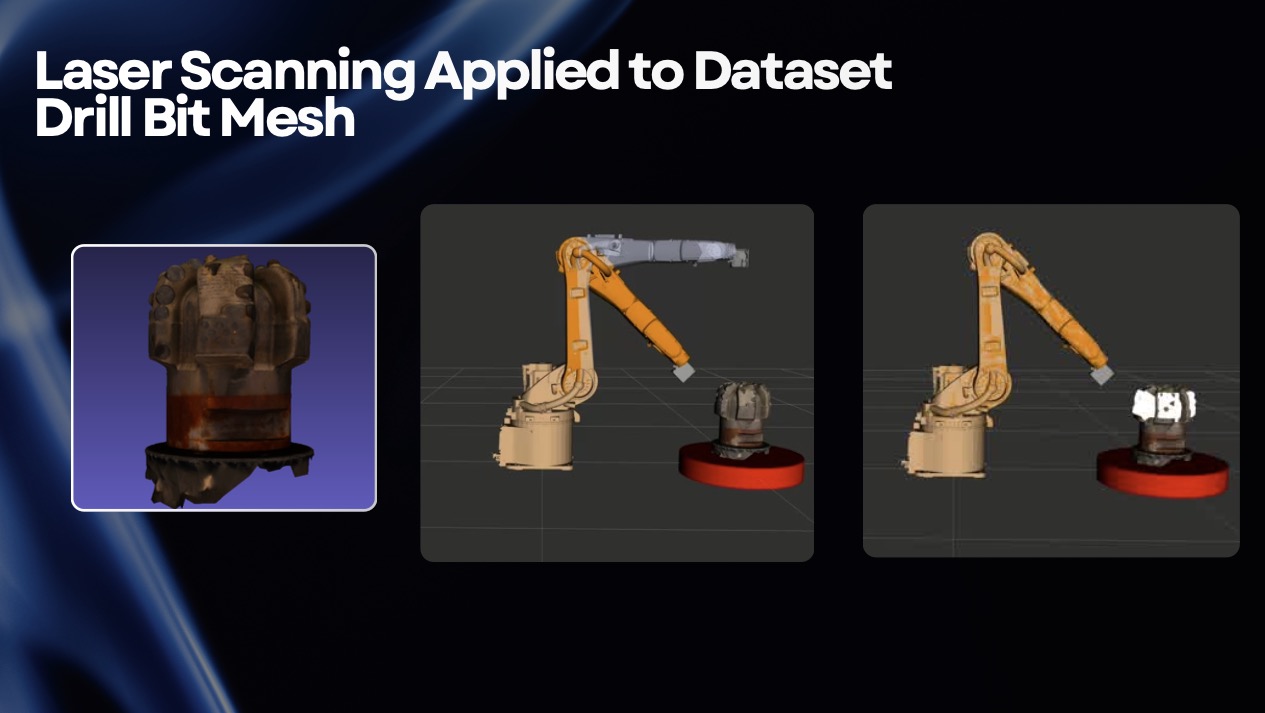
Full digital twin of the scanning system built in ROS/Gazebo/RViz. Simulates a KUKA robotic arm with laser profiler end-effector and drill bit on a rotary table. The GPU LiDAR Gazebo plugin emulates Micro-Epsilon scanControl 2500x100 specifications (100 mm Z-range, 640 points/profile, up to 300 Hz). Any 2D laser profiler can be emulated by replicating its parameters — evaluate configurations without purchasing hardware.
3D-printed adjustable laser profiler mount with 6 degrees of freedom. Custom alignment ring for rotation axis calibration — geometrically points toward the true center, providing visual and algorithmic alignment cues. Designs iterated between CAD simulation and physical prototyping for rapid convergence.
KUKA robotic arm integration for automated scanning and point cloud registration. Multi-angle scanning improves surface coverage. Plans for the HiRoll high-precision mechanical system to enhance stability and alignment of the production setup.
Field Deployment
2-day field visit at Aramco facilities (February 2026). Each bit scanned 8 times: 4 rotational speeds (15, 30, 60, 120 sec/rev) × 2 directions (CW/CCW). Reversing direction reduces laser reflection artifacts from angular misalignment. Gauge measurement results validated against Aramco ground truth.-- Field Trial, Aramco, February 2026
Technology Stack
ROS (Robot Operating System) for sensor integration, motion planning, and point cloud registration across the entire scanning pipeline.
Gazebo for physics-based simulation and RViz for 3D visualization. Full system validation performed entirely in simulation before field deployment.
Micro-Epsilon scanControl 2500 series 2D laser profiler. GPU LiDAR Gazebo plugin configured as 2D profiler for sensor emulation.
KUKA robotic arm for automated multi-angle scanning. Robot URDF model generated from SolidWorks CAD for accurate physical representation.
SolidWorks for mechanical design, URDF generation for simulation, and 3D printing for rapid hardware prototyping of mounts, alignment rings, and fixtures.
Custom algorithms for vertical slicing, minimum enclosing circle computation, mesh generation, and gauge measurement from dense 3D point cloud data.
Challenges & Roadmap
PDC cutter surfaces are highly reflective, causing data dropout in point clouds. Multi-angle scanning helps but requires profiler selection optimized for reflective surfaces.
Precisely determining the rotation axis relative to the laser profiler is critical. Residual offset of ~1 mm persists despite calibration. Uncompensated misalignment introduces systematic bias in gauge measurements.
Planned high-precision mechanical system for improved stability and alignment of the scanning fixture, eliminating mechanical tolerances that propagate into geometric distortion.
New profiler selection better suited for field conditions with improved measurement stability and accuracy on reflective surfaces, expanding the range of inspectable bit types.
Key Differentiators
Full system validated in a digital twin before field deployment, reducing iteration cost and de-risking hardware investments.
The team designs mechanical fixtures, writes ROS nodes, builds algorithms, and deploys to the field — true hardware + software vertical integration.
Demonstrated on real Aramco drill bits with measurable gauge accuracy results. Not a lab prototype — a field-validated system.
Evaluate any laser profiler in simulation before purchasing. Multi-manufacturer drill bit support tested across SLB, Beste, and Ulterra bits of varying sizes.
Get Started
ModusXLabs develops cutting-edge robotics and laser metrology solutions. Contact us to discuss how our technology can serve your inspection needs.